Pranav Yerramaneni
Computer engineering at UC Santa Cruz, class of 2028, and legged-robot research at the HARE Lab. Based in Santa Clara and Santa Cruz, California.
Open to firmware, robotics and applied-ML internships for summer 2027.
- θ
- +0.0°
- ω
- +0 rpm
- τ
- +0 %
A reaction-wheel pendulum under a 240 Hz feedback loop. Drag it, nudge it, or scroll fast, and watch it recover.
-
Undergraduate researcher, HARE Lab, UC Santa Cruz
Santa Cruz · July 2026 to present · JAX · MuJoCo MJX · PPO · Python
-
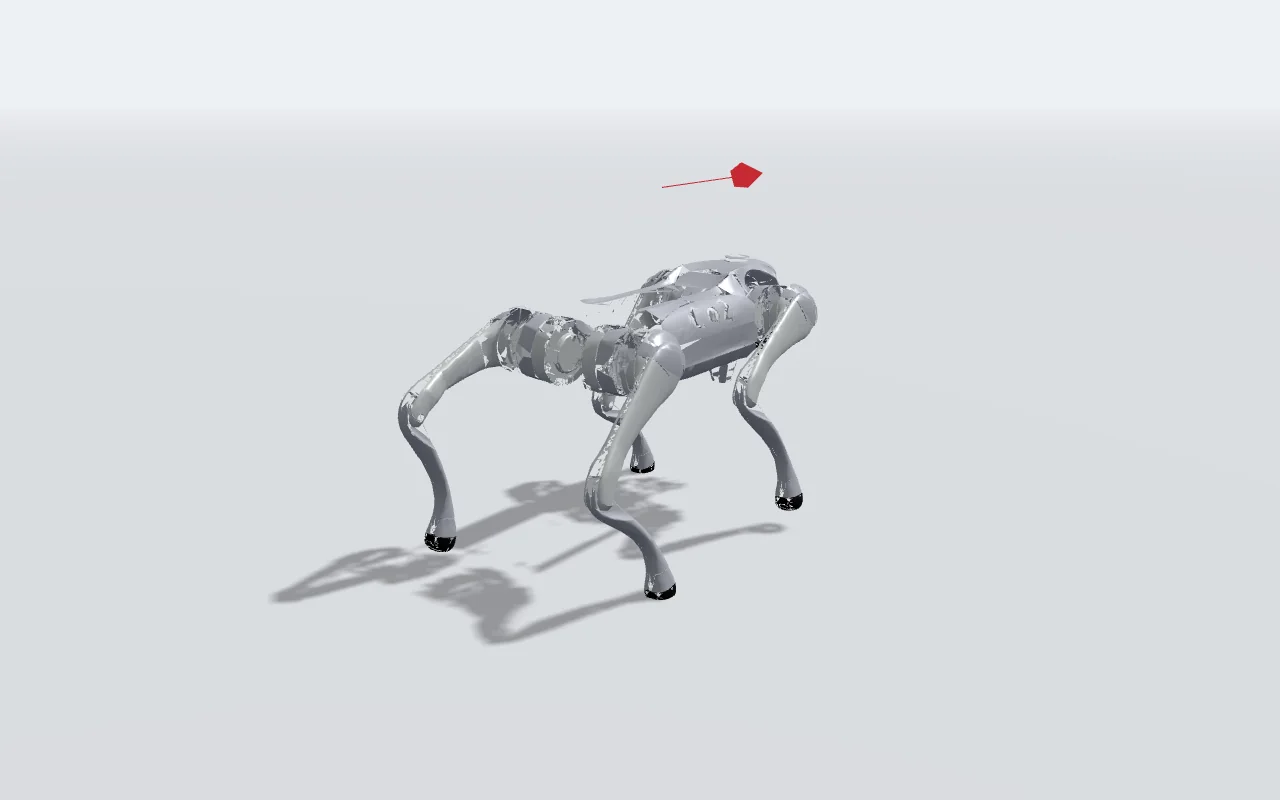
This is the walking policy I trained, live: MuJoCo in WebAssembly at 500 Hz, the network at 50 Hz. I am putting the same policy file on the real robot. Click it, then W A S D to move, Q E to turn, Space to push.
-
-
Dual-reaction-wheel humanoid balance
2024 to 2025 · C++ · Teensy 4.1 · Python · Raspberry Pi · ODrive CAN
-
Firmware engineer intern, Nova Robotics ↗
Santa Clara · February 2025 to March 2026 · Python · C++ · C# · CUDA · ODrive CAN · Unity/OpenXR
-
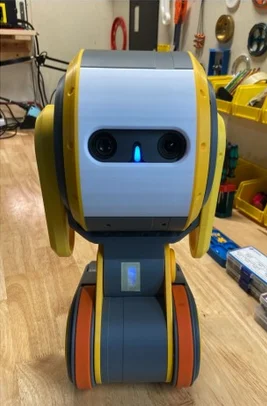
Rokx, Nova's robot: ZED stereo cameras for eyes, a two-axis head and neck, an arm and drive wheels on five ODrive motors, which I drive from a Raspberry Pi over dual 1 Mbps CAN. -
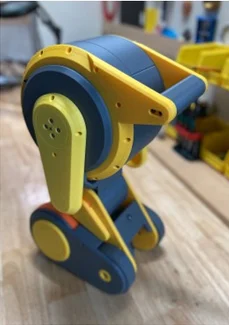
On the Jetson Nano, I fine-tuned a quantized LLaVA vision-language model with LoRA adapters to run at 15+ FPS, up from 1 to 2, and gave VibeVoice text-to-speech a streaming OpenAI-compatible server (pull request 59): audio from the first token. -
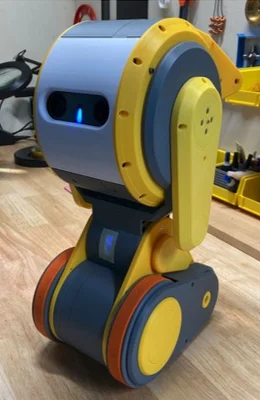
I built the Meta Quest teleop in Unity/OpenXR: 60 Hz head tracking drives the head and neck, stereo ZED video comes back. WebSockets and hardware encoding cut latency from 1.2 s to under 100 ms; UDP discovery makes setup zero-configuration.
-
-
Co-founder and lead engineer, CometKits ↗
Santa Clara · September 2022 to June 2025 · C/C++ · ESP-IDF · EasyEDA · Blockly · PlatformIO
-
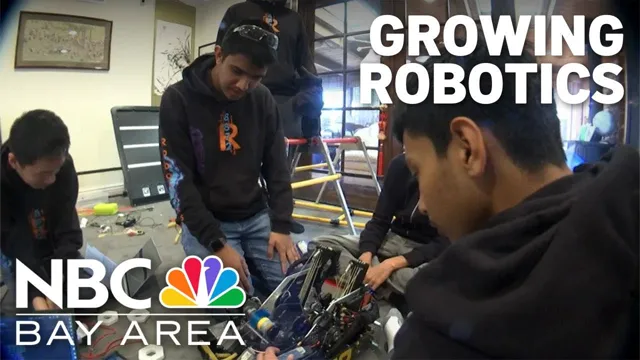
Low-cost robotics kits for elementary schools. I co-founded the program and wrote the ESP-IDF firmware for its custom ESP32 boards; 500+ students so far, recognized by the mayor and covered by NBC Bay Area.
-
-
FTC Team 8872, Robopocalypse ↗
Wilcox High School · 2022 to 2025 · Java · FTC SDK · Road Runner · OpenCV
-
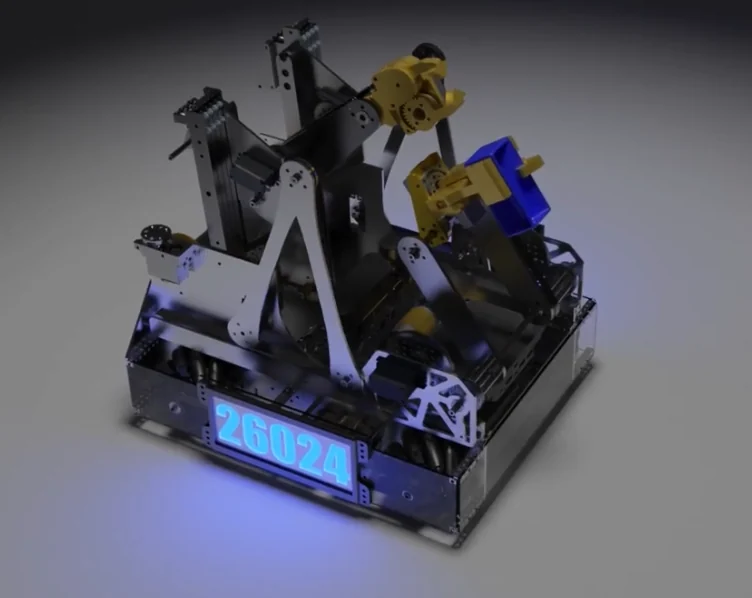
The robot rendered from its CAD model. I led the five-person software crew that wrote its Road Runner motion planning, OpenCV vision and autonomous routines in Java on the FTC SDK.
-
